JumpGrad: Differentiable Optimization through Stochastic Mechanics
An end-to-end control framework for stochastic stick-slip mechanics, connecting a learned controller with physical simulation and custom gradients while retaining hard discrete switching events.
JumpGrad connects a learned controller to a mechanical simulator to optimize vibration control under stochastic switching. The physical simulation retains hard LOW/HIGH actuator events. A custom gradient based on finite differences with shared random samples connects the mechanics to the controller for end-to-end optimization.
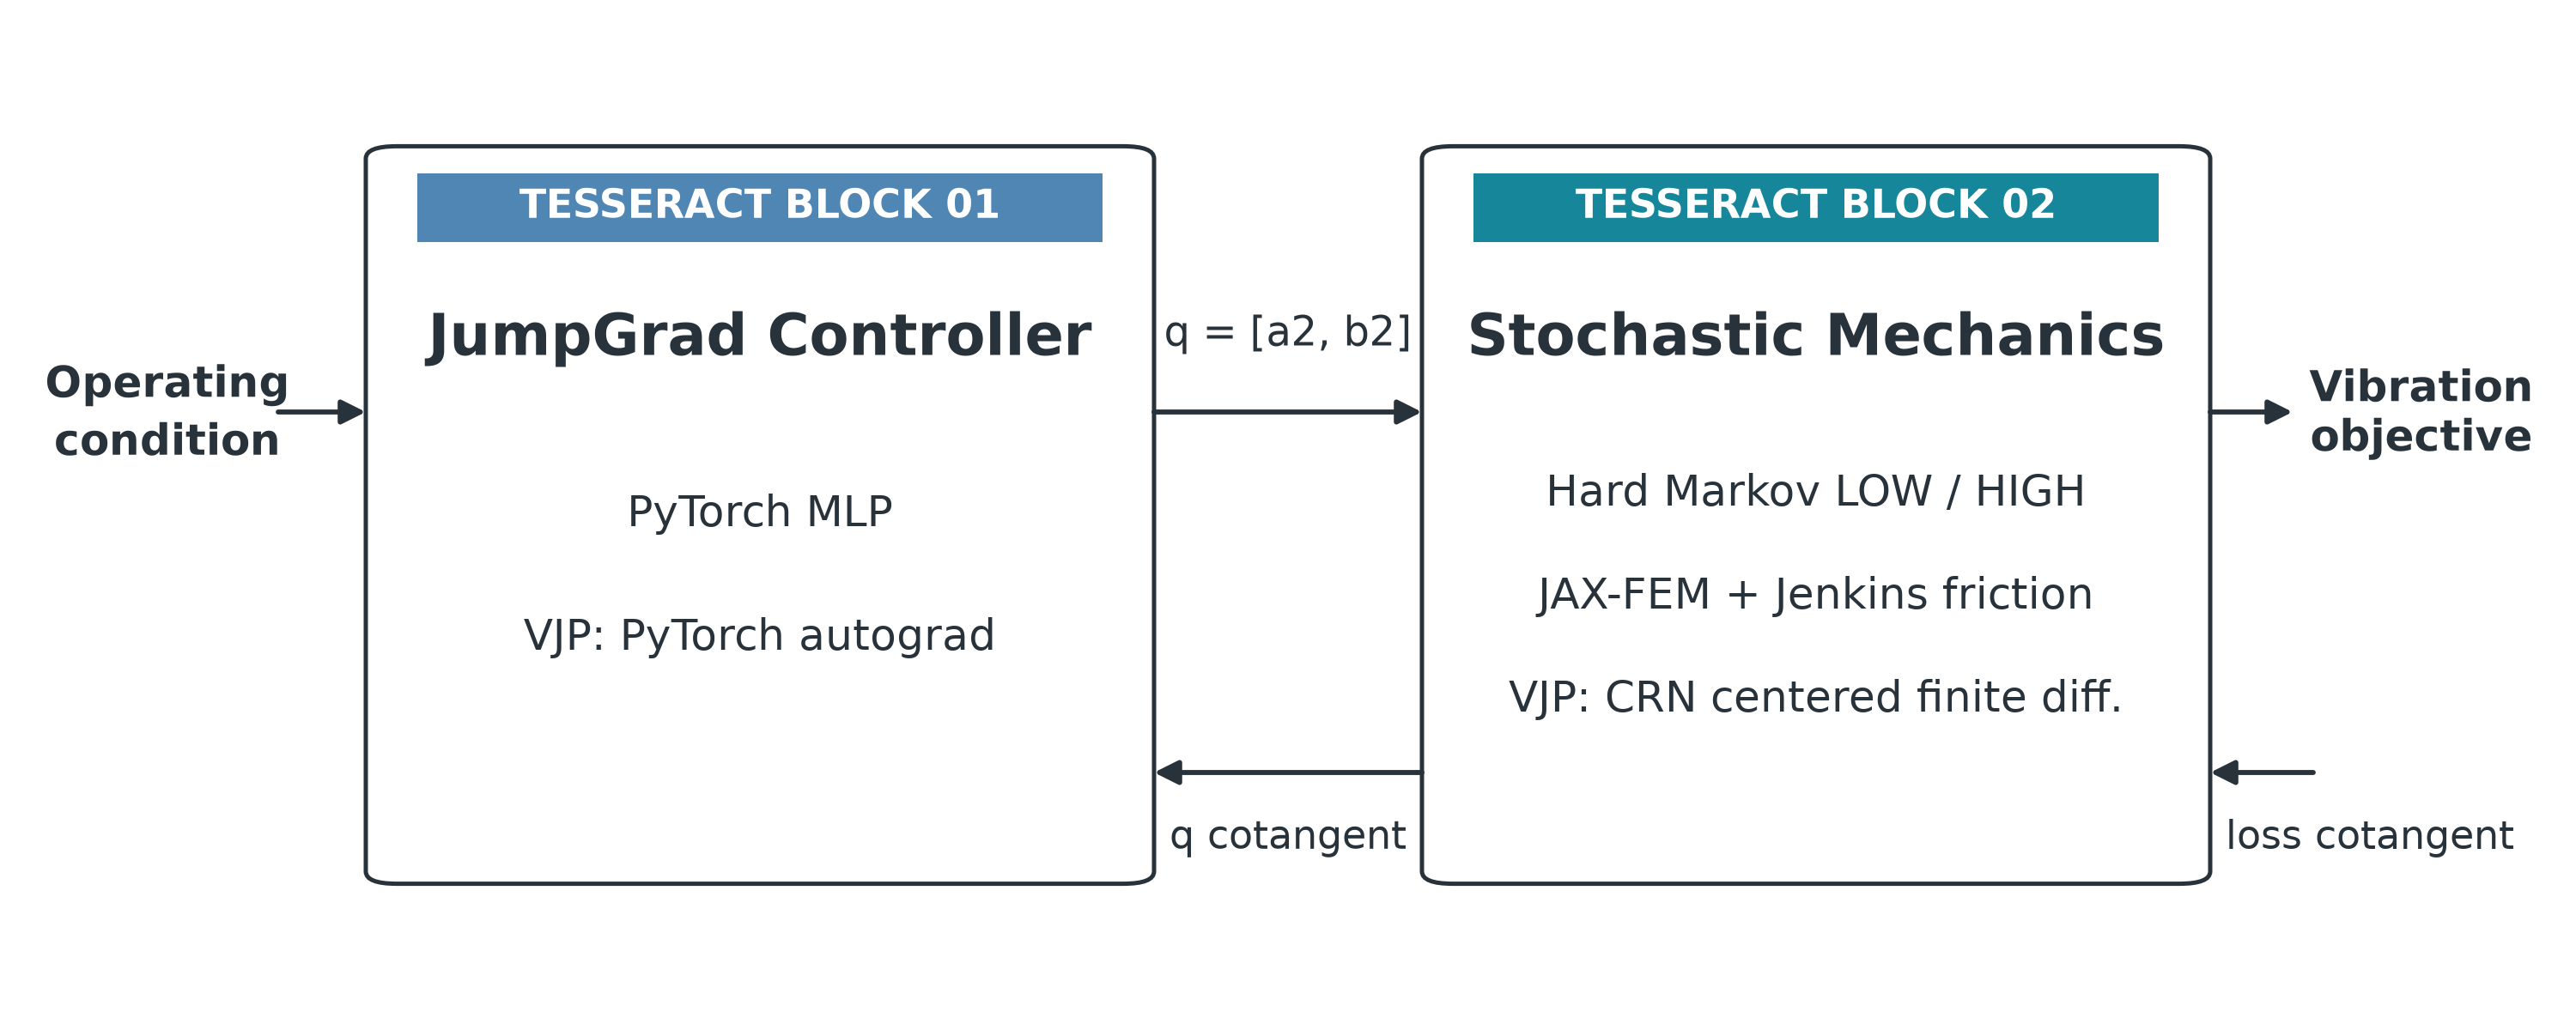
The diagram is reproduced from the JumpGrad repository, licensed under Apache 2.0.